Robotics Insights & Chronicles
In-depth technical reflections, hardware teardowns, rover milestone logs, and competition updates authored by the engineers at KRS.
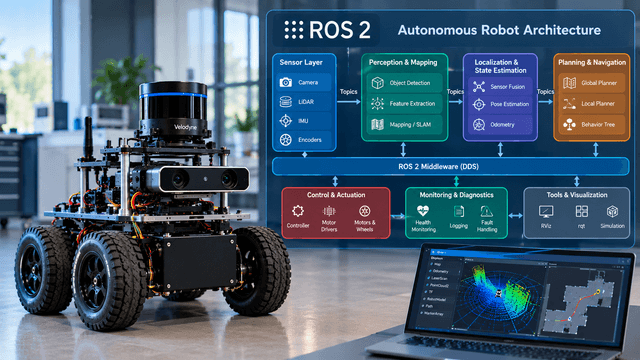
Designing a Production-Style ROS 2 Architecture for Autonomous Robots
Building an autonomous robot requires more than connecting sensors and writing movement commands. A production-style ROS 2 architecture organizes sensing, perception, localization, planning, control, and diagnostics into reliable, maintainable software components. This article explores ROS 2 nodes, topics, services, actions, lifecycle management, quality-of-service settings, fault handling, and practical engineering principles for building scalable robotic systems.
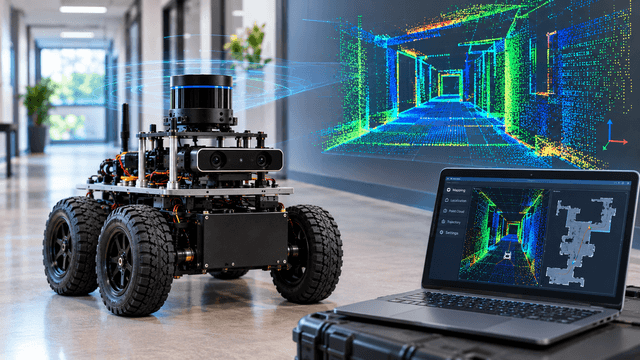
SLAM Explained: How Autonomous Robots Build Maps and Locate Themselves
Simultaneous Localization and Mapping (SLAM) enables autonomous robots to explore unfamiliar environments while building maps and estimating their own positions. This article explains how SLAM works, the sensors and algorithms involved, practical implementation with ROS 2, common challenges, and real-world applications.
IMU, Encoder, LiDAR and Camera Fusion: Building a Reliable Robot State Estimate
Autonomous robots rely on accurate knowledge of their position, orientation, and motion to navigate safely. However, no single sensor provides a complete and consistently reliable picture of the robot's state. This article explores how IMUs, wheel encoders, LiDAR, and cameras complement one another, how sensor fusion works, and how engineers build robust state-estimation systems for real-world robotics.
Anatomy of an Autonomous Robot: From Sensors to Decisions and Actuation
An autonomous robot is an integrated system that senses its surroundings, estimates its state, plans actions, and executes movements without requiring continuous human control. This article explores the theory behind autonomous robotics, including sensor fusion, localization, motion planning, control systems, embedded computing, and the feedback loops that enable robots to operate in dynamic environments.
How to Prepare for the KRS Robotics & AI Hackathon 2026
Strategic advice on assembling multidisciplinary teams, planning hardware component kits, and preparing for the 12-hour national challenge.
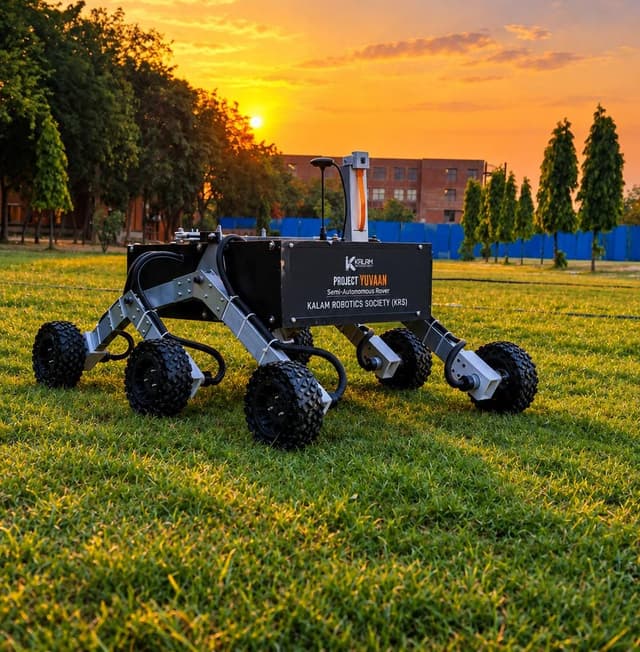
Building YUVAAN: From Kinematic CAD Models to Field Traversal
An engineering deep-dive into the design iterations, suspension geometry, and sensor fusion algorithms powering the KRS flagship rover.