KALAM ROBOTICS
SOCIETY
The premier cyber-physical systems laboratory at IILM University. Advancing autonomous mobile robotics, real-time edge intelligence, and national technical competition excellence.
Pioneering Applied Robotics
Kalam Robotics Society (KRS) is the premier multidisciplinary student robotics and cyber-physical systems laboratory at IILM University, Greater Noida. Founded to foster advanced hands-on experimentation, applied research, and national competitive excellence, KRS empowers aspiring engineers across mechanical, electronic, and software domains.
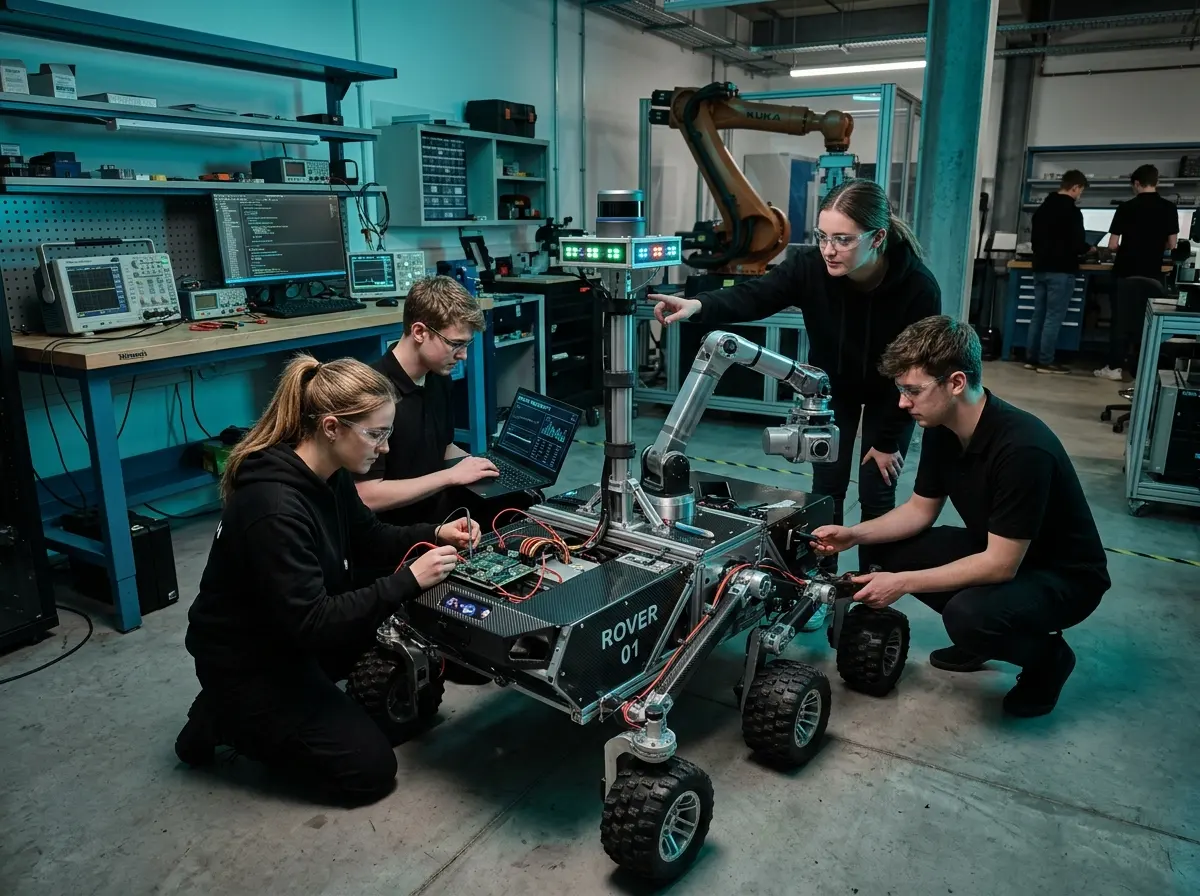
Applied Engineering Labs
Hands-on hardware workbench equipped for rapid prototyping, microcontroller programming, and component assembly.
National Competition Circuit
Representing university excellence across elite robotics challenges, rover competitions, and AI hackathons nationwide.
Peer-to-Peer Technical Pedagogy
Structured workshop bootcamps and open technical roadmaps taking members from fundamentals to advanced ROS2 workflows.
Industry & Research Synergy
Collaboration with technical mentors, faculty advisors, and domain specialists on production-grade prototypes.
Upcoming Event
Don't miss our biggest event of the season. Register now to secure your spot!
AURIX 2026: National Robotics Arena & AI Challenge
- Compete in Robo Soccer, Robo Race, Robo Expo and Robo Ideathon
- Robotics & AI Hackathon with an online first round
- ₹2,10,000 total prize pool
Engineering Rigor in Every Discipline
Kalam Robotics Society is built for ambitious engineers ready to design, prototype, and compete across robotics disciplines.
The Hardware Builders
You keep tinkering with electronics. But nobody's given you access to a dedicated lab workbench until now.
The Arena Competitors
You know competitions are where reputations are made. You're looking for a crew to build winning robots with.
The Systems Architects
You've spent years writing code. Now you want to see your algorithms control physical machines in real time.
The Competition Toolkit
Six competitions, two arena days at IILM University. Pick your challenge.
AI Hackathon 2026
12-hour national challenge tackling 9 domains with a ₹1,00,000 prize pool.
₹749 / team · 1–5 Members
AURIX Robo Race
₹499 per team. Teams of 1–3 members. Manually controlled, max 30 × 30 × 20 cm and 5 kg.
₹499 / team · 1–3 Members
AURIX Robo Expo
₹499 per team. Teams of 1–4 members. Present, demo and defend your robot — judged out of 100.
₹499 / team · 1–4 Members
AURIX BGMI Tournament
BGMI tournament at IILM University, Greater Noida, on 28 October 2026: Solo ₹99 or Squad ₹199 (1–4 players). Tournament Mode: Online and in Campus. Single day event. ₹10,000 prize pool.
₹99 solo · ₹199 squad · 1–4 Members
AURIX Robo Soccer
₹499 per team. Teams of 1–3 members. Wireless robots, max 30 × 30 × 25 cm and 5 kg.
₹499 / team · 1–3 Members
AURIX Robo Ideathon 2026
₹399 per team. Up to 5 members. Not a robot-building competition — physical hardware is optional.
₹399 / team · 1–5 Members
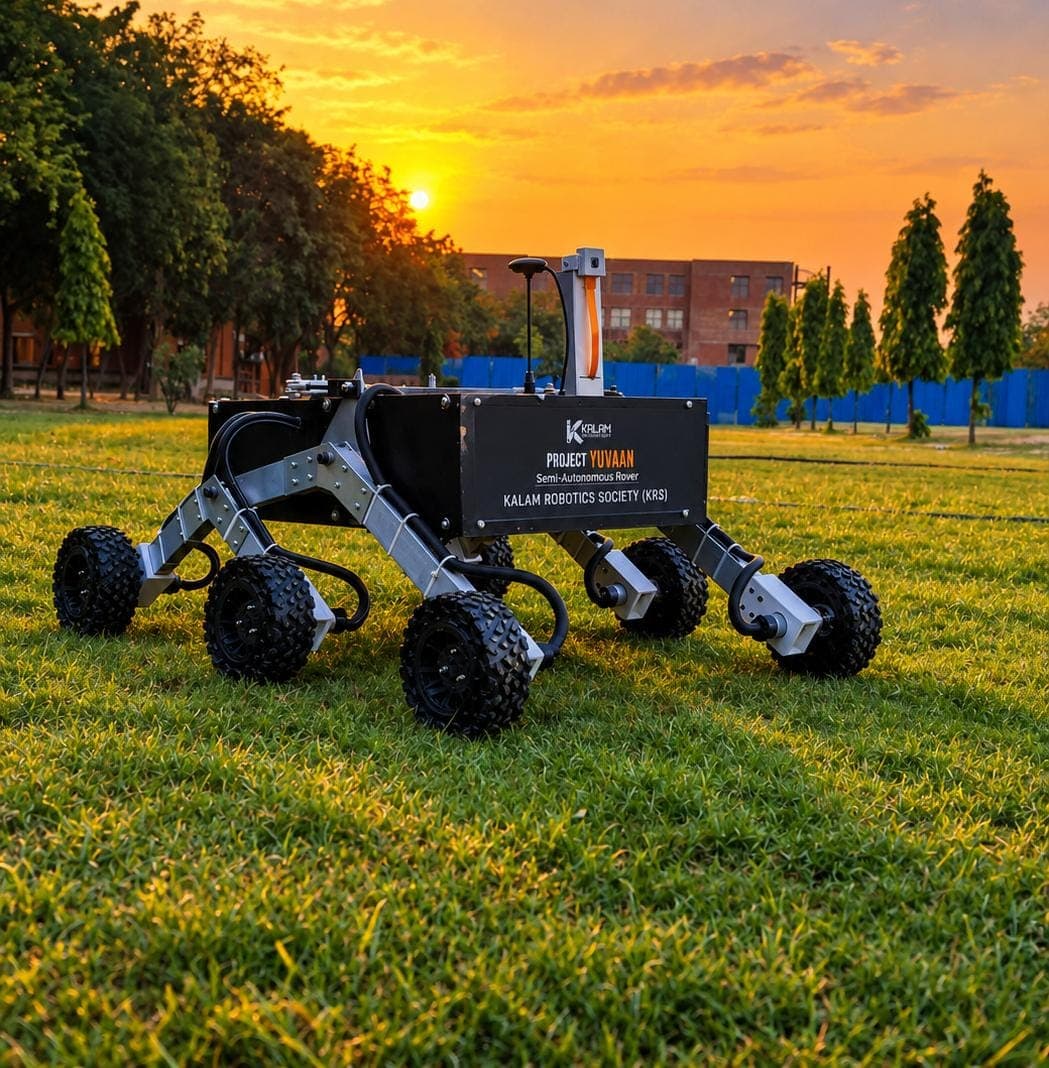
YUVAAN Semi-Autonomous Rover
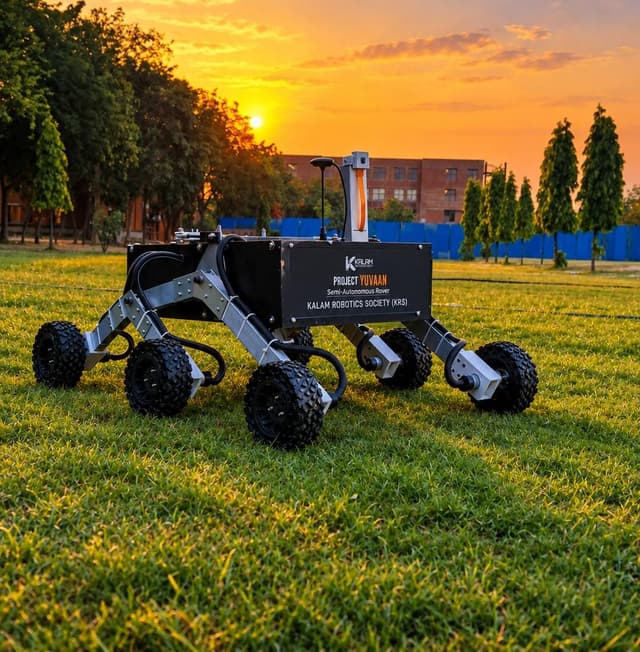
YUVAAN is the flagship integrated robotics project of Kalam Robotics Society (KRS), developed at IILM University. The rover combines in-house mechanical fabrication (T-slot chassis, rocker-bogie suspension, six geared drive wheels) with split low-level motor control on STM32 and high-level perception, navigation, and telemetry on Raspberry Pi 5. Operators use manual control or GPS-based autonomous waypoints; onboard vision supports live streaming and intelligent monitoring. A React ground-control station provides telemetry, map view, waypoint planning, and system diagnostics over WebSocket and HTTP.
Successfully demonstrated waypoint navigation, autonomous obstacle avoidance in unstructured environments, and 45-minute continuous mission endurance.
- High-torque planetary gear motors with optical quadrature encoders
- Dual stereoscopic depth cameras for real-time visual odometry
- Custom power distribution PCB with dual-rail voltage regulation and telemetry
- Solid-state IMU with Kalman filter fusion for pitch/roll compensation
- ROS2 Humble architecture with distributed node topology
- Nav2 2D/3D costmap generation and dynamic obstacle avoidance
- Low-latency WebRTC teleoperation control panel
- Real-time edge object detection pipeline running on onboard accelerator
Latest Engineering Blogs & Stories
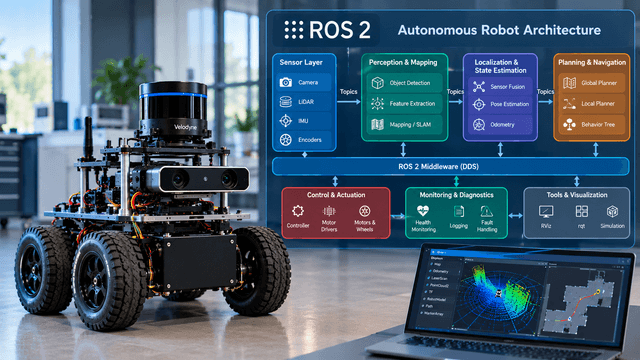
Designing a Production-Style ROS 2 Architecture for Autonomous Robots
Building an autonomous robot requires more than connecting sensors and writing movement commands. A production-style ROS 2 architecture organizes sensing, perception, localization, planning, control, and diagnostics into reliable, maintainable software components. This article explores ROS 2 nodes, topics, services, actions, lifecycle management, quality-of-service settings, fault handling, and practical engineering principles for building scalable robotic systems.
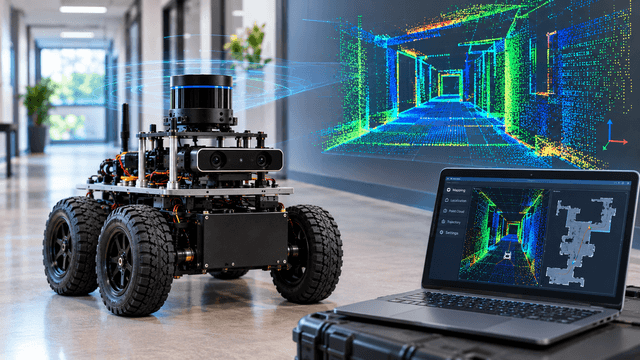
SLAM Explained: How Autonomous Robots Build Maps and Locate Themselves
Simultaneous Localization and Mapping (SLAM) enables autonomous robots to explore unfamiliar environments while building maps and estimating their own positions. This article explains how SLAM works, the sensors and algorithms involved, practical implementation with ROS 2, common challenges, and real-world applications.