YUVAAN Semi-Autonomous Rover
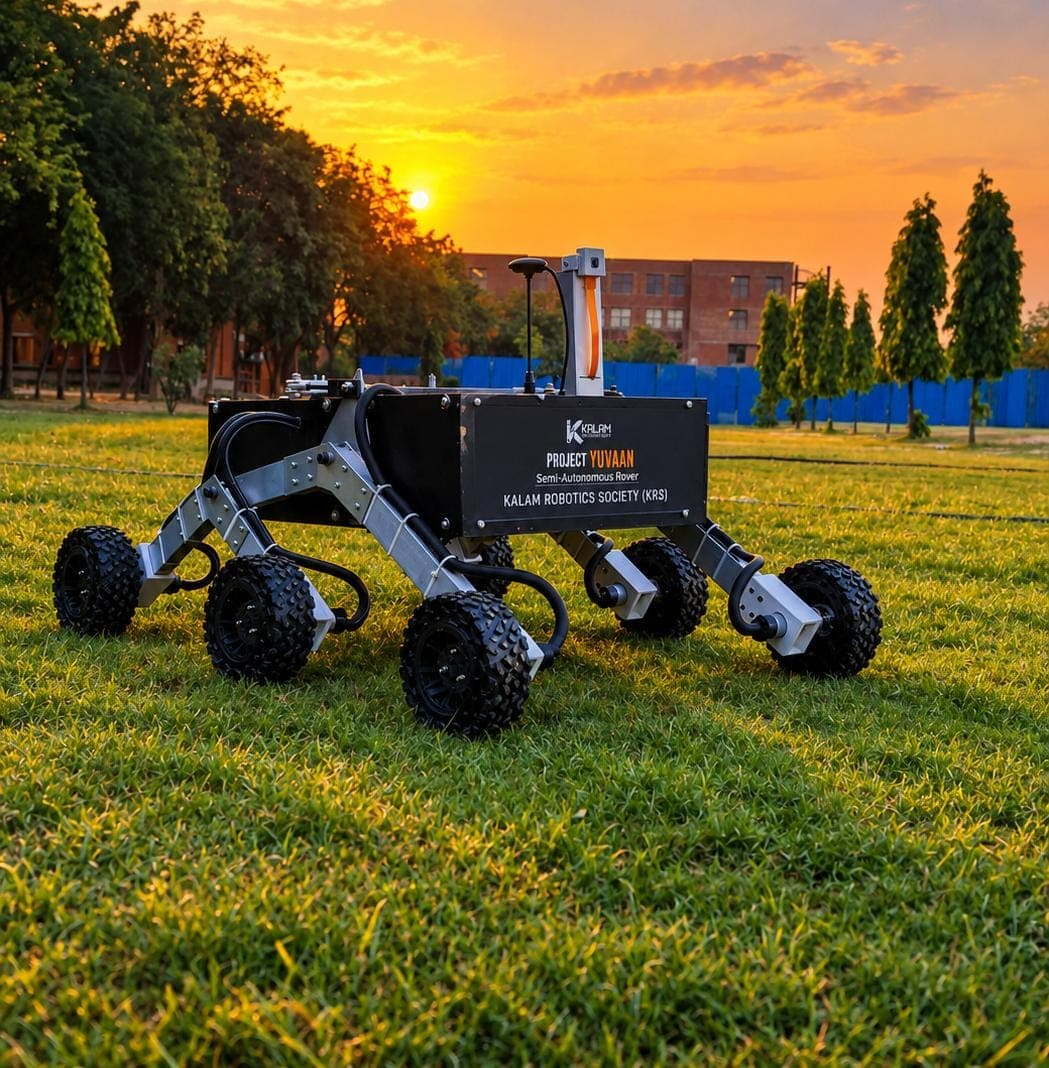
YUVAAN is the flagship integrated robotics project of Kalam Robotics Society (KRS), developed at IILM University. The rover combines in-house mechanical fabrication (T-slot chassis, rocker-bogie suspension, six geared drive wheels) with split low-level motor control on STM32 and high-level perception, navigation, and telemetry on Raspberry Pi 5. Operators use manual control or GPS-based autonomous waypoints; onboard vision supports live streaming and intelligent monitoring. A React ground-control station provides telemetry, map view, waypoint planning, and system diagnostics over WebSocket and HTTP.
- •High-torque planetary gear motors with optical quadrature encoders
- •Dual stereoscopic depth cameras for real-time visual odometry
- •Custom power distribution PCB with dual-rail voltage regulation and telemetry
- •Solid-state IMU with Kalman filter fusion for pitch/roll compensation
- •ROS2 Humble architecture with distributed node topology
- •Nav2 2D/3D costmap generation and dynamic obstacle avoidance
- •Low-latency WebRTC teleoperation control panel
- •Real-time edge object detection pipeline running on onboard accelerator
Tested Operational Benchmarks
Successfully demonstrated waypoint navigation, autonomous obstacle avoidance in unstructured environments, and 45-minute continuous mission endurance.